microduck
by pollen-robotics
Official Microduck runtime (Rust daemon, robotctl, policy manifest, web app). XL330 servos, RK3566.
GitHub · licence Apache-2.0 · 9,112 stars
Huey stands on a lot of open work. Open Duck Mini by Antoine Pirrone and Microduck by Pollen Robotics started this family of small walking robots, and hundreds of people have built on them since: new bodies, trained networks, simulators, tools and videos. Here are 515 of their projects, each credited to the people who made it.
Huey is our own robot, made in Shenzhen. It is not a Pollen Robotics product and not endorsed by any project below. Every project belongs to its author and keeps its own licence; "none stated" means the author has not given a licence, so ask them before reusing it. Details as fetched on 2026-10-05.
Official Microduck runtime (Rust daemon, robotctl, policy manifest, web app). XL330 servos, RK3566.
Open Duck Mini v2: Onshape CAD, BOM, assembly, docs, Discord. 42 cm, 14 STS3215, Pi Zero 2W, BNO055.
Official RL training (mjlab): walk, VelStand, SitStand, StandUp, roulade, roller, kick tasks; MJCF + 47 STL meshes.
MuJoCo Playground (MJX/Brax) RL envs for Open Duck Mini v2 and BDX.
Python runtime for Open Duck Mini: Feetech STS bus, IMU, ONNX walk policy, gamepad teleop, head/antenna/eye/sound expressions.
Placo-based reference gait generator feeding imitation rewards.
Blender model of Open Duck Mini for animation.
Prebuilt aarch64 GStreamer plugins (Rockchip MPP encoder) for the Microduck camera stream.
Open Micro Duck build for everyone (replica hardware + docs).
Fanduck: a working Microduck replica with demo, BOM and notes.
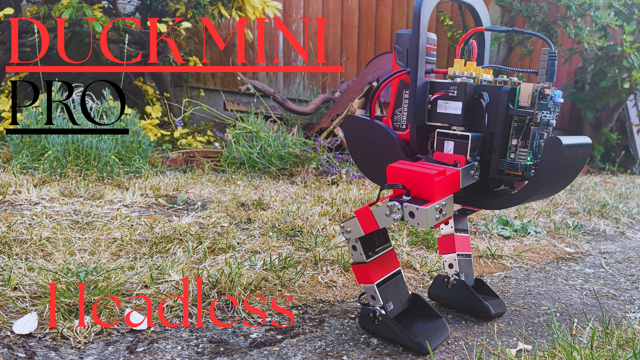
10-DoF headless biped on ST3025 Feetech servos, RL-trained.
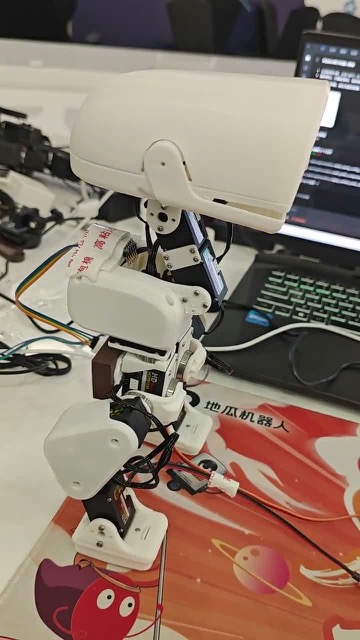
Microduck on RDK X5 with HD1910M servos: assembly, servo and IMU bring-up, short walk.
Community replica: 39 STL, 11 print projects, HD-1910 fit.
Jetson Orin Nano port with Unitree S288 servos and their bus protocol.
Snapshot of apirrone's deleted prototype microduck_runtime (March 2026).
Microduck walk policy at 50 Hz on an ESP32-S3, INT8 weights.
Rust port of the Open Duck Mini runtime.
Measurement-first Open Duck Mini runtime for RDK X5.
Flamingo (one-leg) cycle policy, Pollen engineer.
Official ONNX set: velstand, roulade, alpha_sitstand, alpha_stand, alpha_walking, alpha_ground_pick, kicks, roller.
Headstand routine in sim: fold, kick-ups, split switch, back roll (policies on HF).
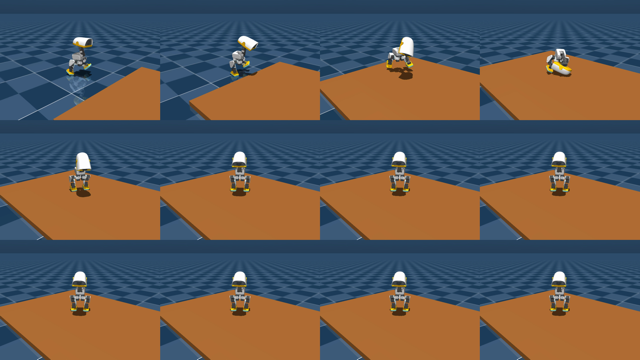
25 mm step-up and head-brake recovery policies, sim-validated, with source.
Step-up + head-brake recovery, two-policy controller.
Episodic 6 s stand-up policy, robotctl manifest.
Roulade policy (Pollen engineer, Arena).
Roulade policy, early checkpoint.
VelStand policy from apirrone (Microduck Arena).
Base stand policy from Microduck Academy.
Roulade retrained with the upstream recipe.
Official sit/stand retrained from scratch with the upstream recipe, with fidelity report.
Forward roll from standing, sim only.
Get-up policy v2 with +-1 deg backlash: face-down 3/3, sitting 3/3, back 0/3 (sim).
Walk-and-recover with backlash (stays up 6/7; does not get up from lying).
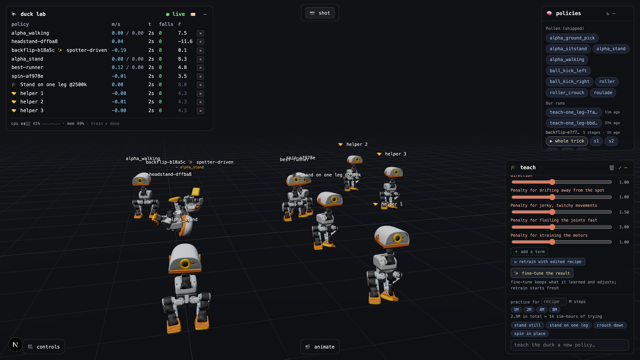
Train Microduck policies on a Mac without CUDA, watch them live.
Reproducible RL experiments, policies, sim assets and hardware add-ons.
RL training for XGO-Duck (Feetech 1910 actuator model).
PyTorch-native Microduck sim and training via mujoco-torch.
Isaac Lab 3.0 / Newton envs for Microduck.
microduck_rl fork with an HD1910 actuator model covering all upstream tasks.
Open_Duck_Playground fork for Rhoban's Sigmaban humanoid.
CAD and MuJoCo experiments: walking, sit/stand, recovery, jaw.
RL scripts teaching Open Duck Mini to stand.
Official browser simulator (614 likes).
Interactive anatomy explorer.
ROS 2 Jazzy + Isaac Sim integration.

3v3 RL football in the browser (MuJoCo WASM).
Simulation models for OpenDuck and motion generation.
ROS 2 URDF/xacro description package.
Official policy playground.
ROS 2 description and joint controllers for Open Duck Mini.
Hardware and software setup tutorial for a Microduck-class RL biped.
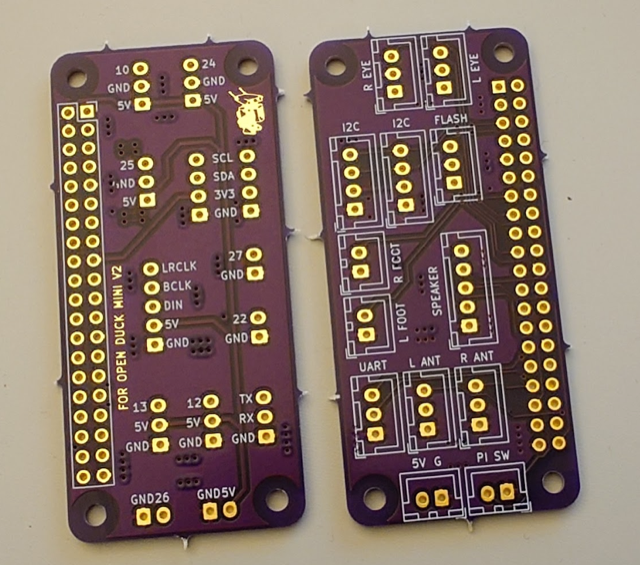
Pi HAT that simplifies Open Duck Mini wiring.
Missing Microduck circuits and firmware, test tools (imu_to_dxl).
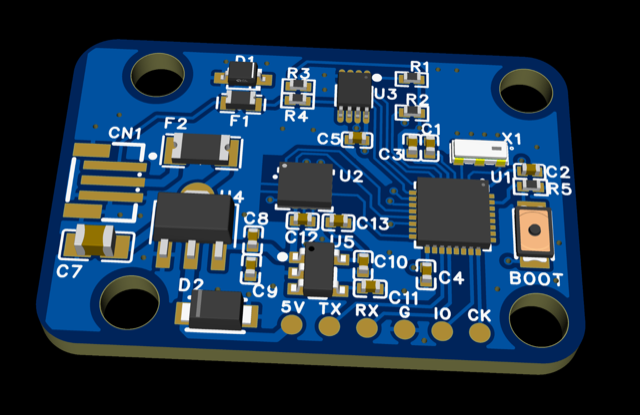
Torso IMU board for Microduck (IMU to TTL bus).
35 mm FOC driver for a GBM2804 gimbal motor that answers on the Open Duck Mini's servo bus as a Feetech servo.
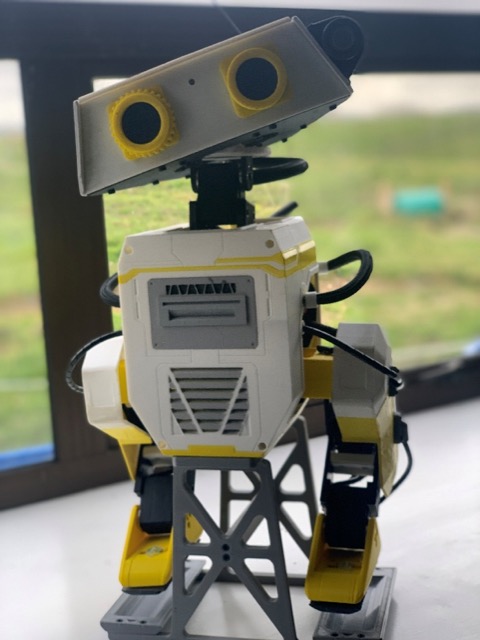
LCD eyes with expression animations for Open Duck Mini v2.
Display stand for Open Duck Mini.
Desktop Microduck that reacts to Claude Code / Codex activity.
Official console space.
Viewer for Open Duck Mini models and motions.
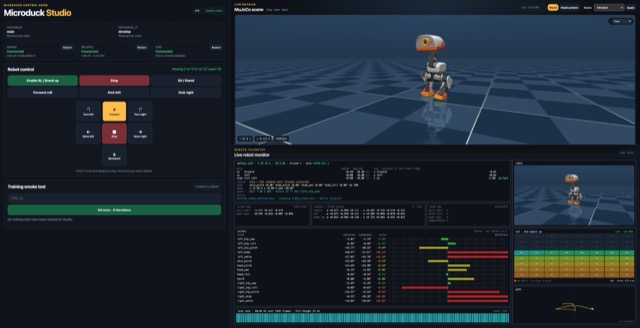
Local web studio to develop, debug, visualise and orchestrate Microduck.
Animation tool for Open Duck Mini.
Microduck in pure Swift: real policies and kinematics, no dependencies.
Qt desktop tool for Feetech/Waveshare SCS and STS bus servos.
Assembly drawings and CAD assembly reverse-engineered from the official MJCF and Rust source.
Editable SolidWorks model and a 21-page assembly manual.
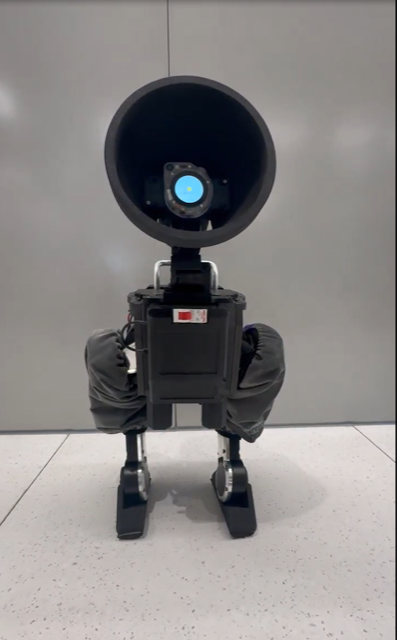
Tinker: a high-performance biped mixing Pixar lamp and Disney BDX styles, full hardware + RL.
mjlab RL for the full-size BDX-R (Robstride motors, Kayden Knapik).
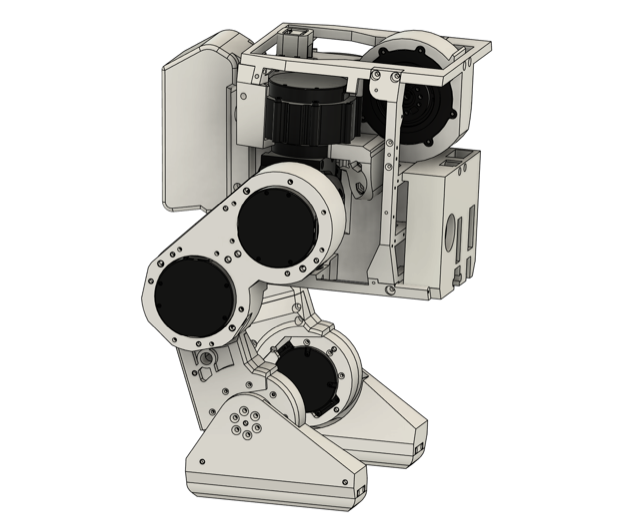
CAD, URDF and USD for the full-size BDX-R.
USD description of Disney's BD-X.
BDX droid using Open Duck Mini v2 electronics.
Floyd: 8-DOF BDX-style biped, mechanical, PCB, Isaac Lab.
Official emotions dataset (expressive motions).
Agent-agnostic CLI for controlling Microduck.
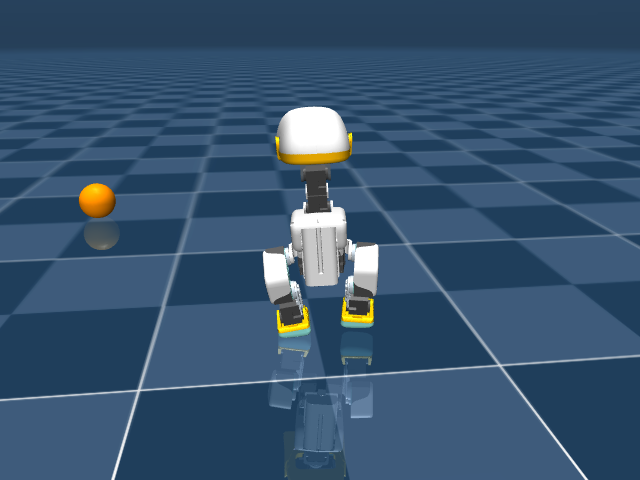
MCP server to drive Microduck (sim) from any MCP client.
Curated awesome list: software, sims, policies, agent tools, press.
437 projects